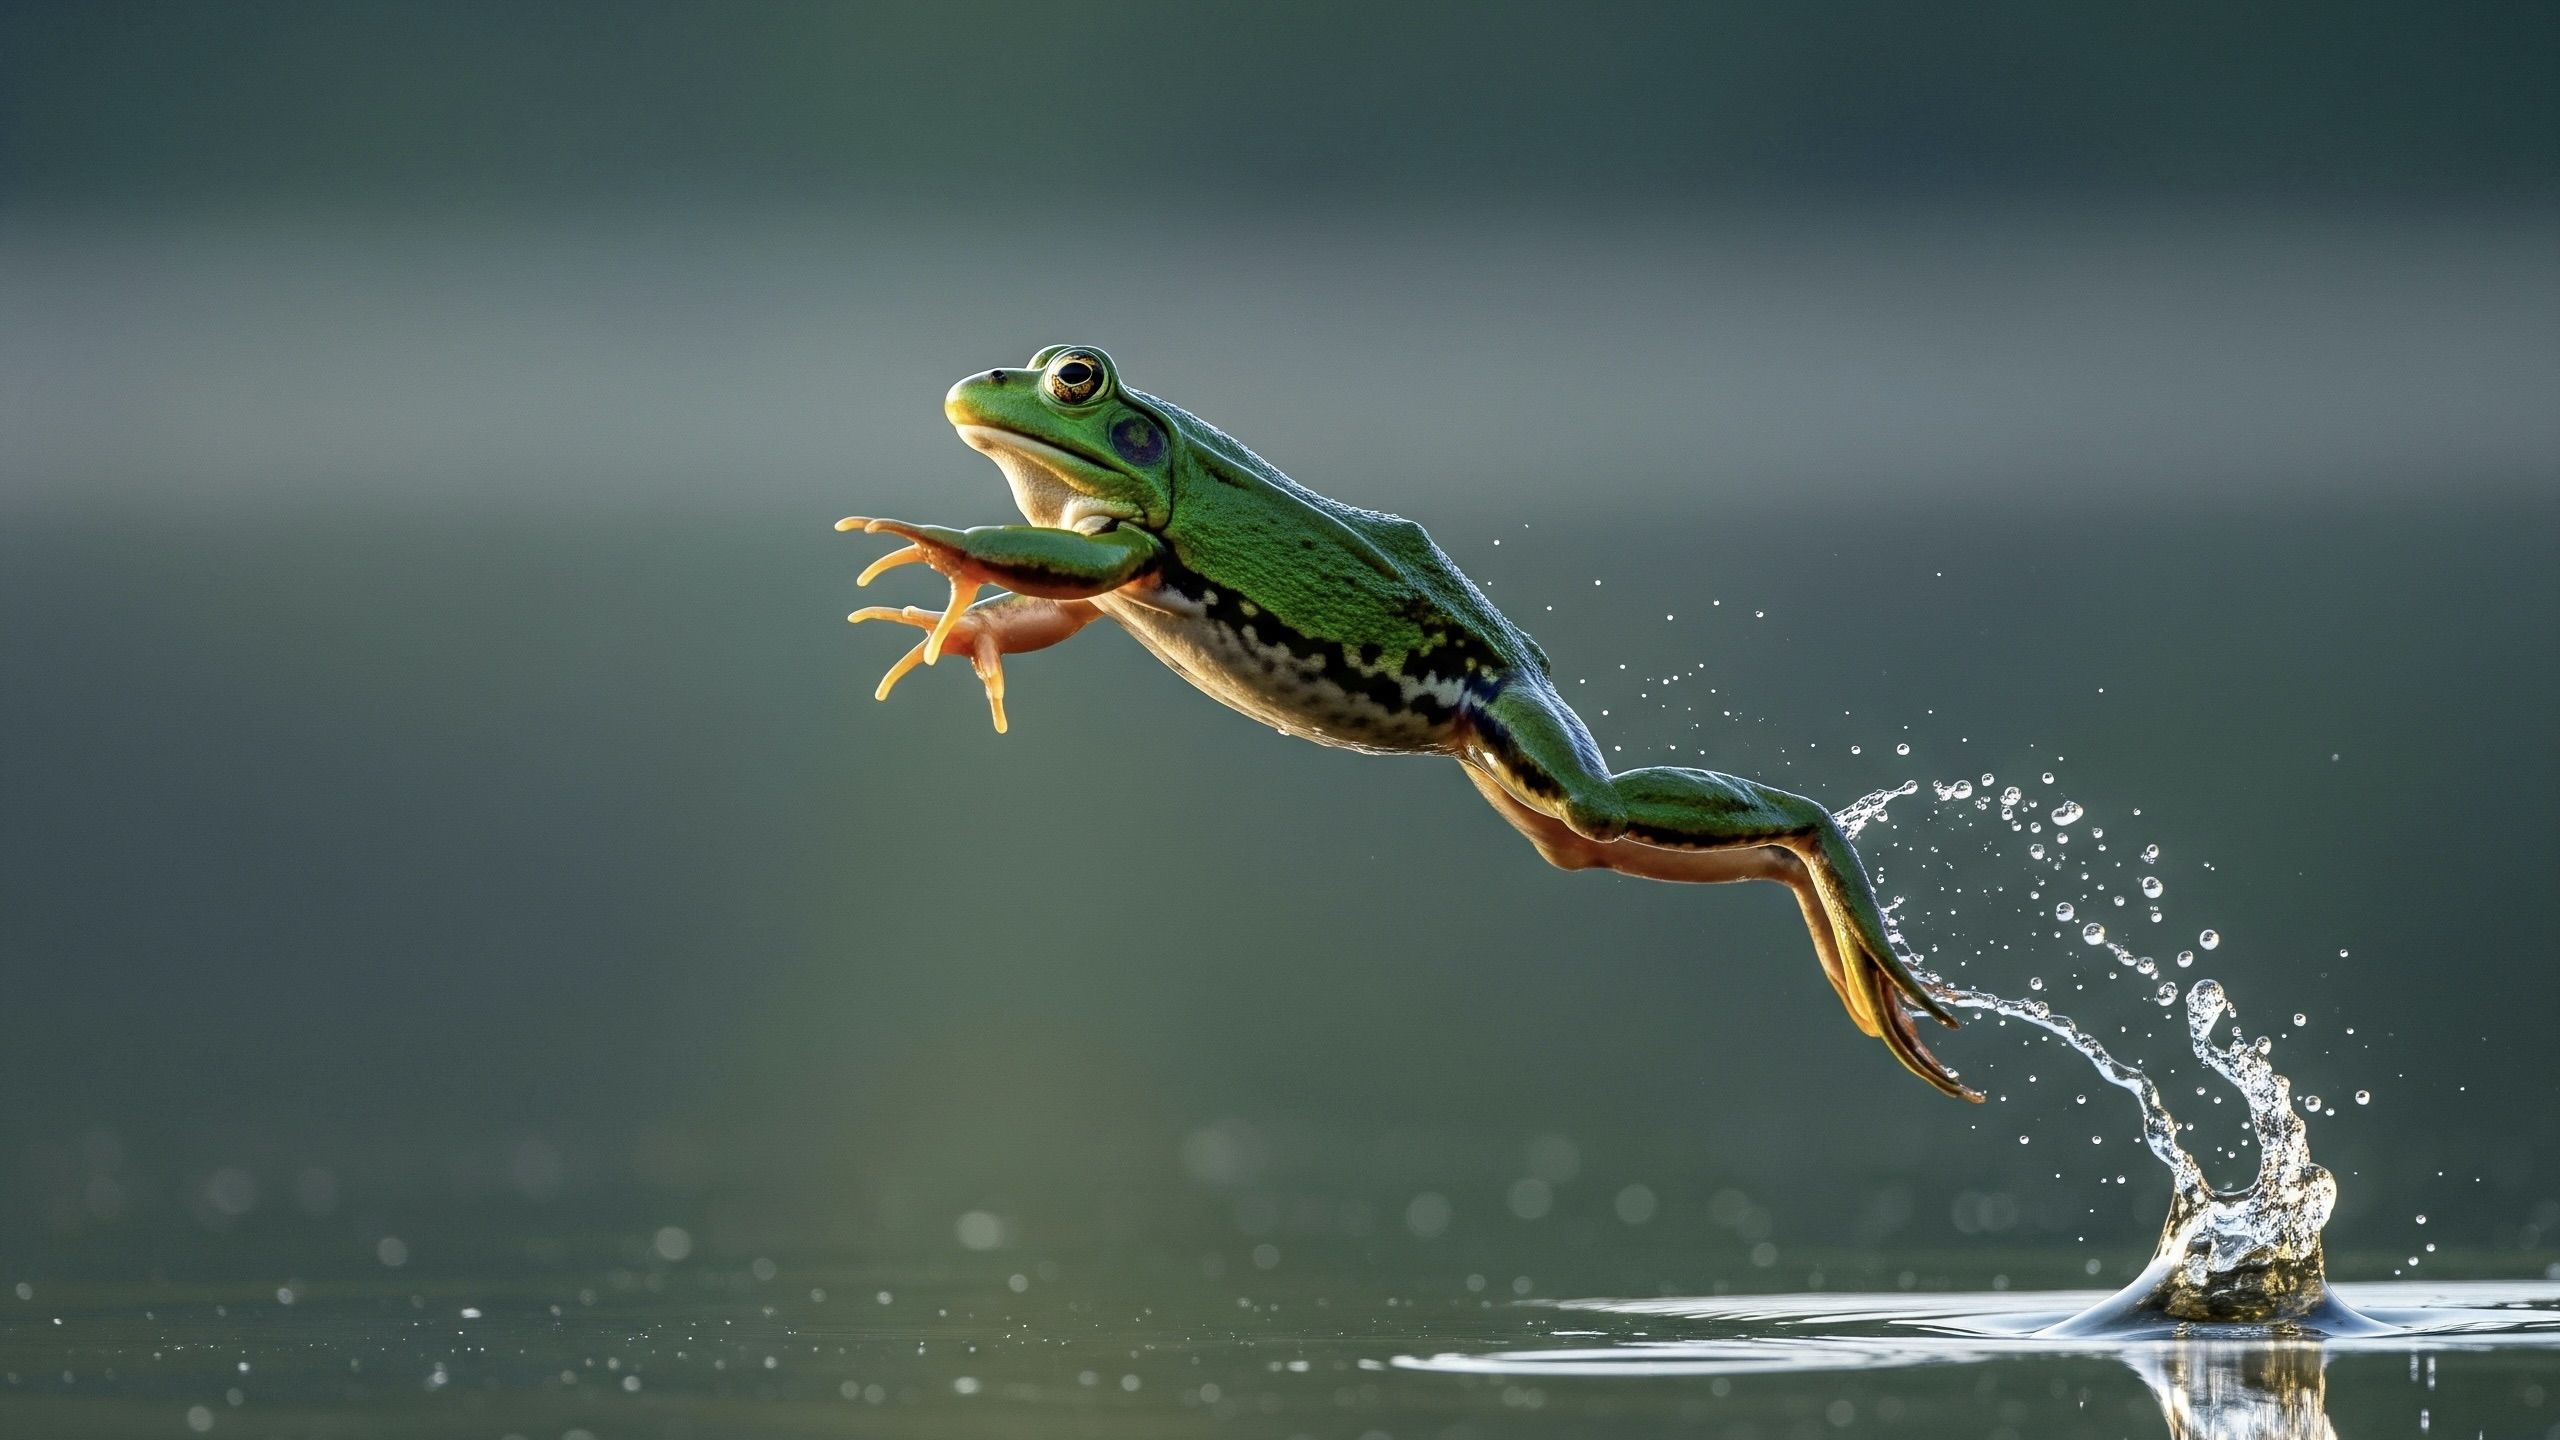
Roboticists have taken inspiration from horses, insects and countless other animals in their pursuit of better propulsion. Now frogs are joining that list. A team of researchers has demonstrated a palm-sized robot that borrows the amphibian's knack for sudden, forceful leaps, using a mechanism built around bent elastic rods that snap from one shape to another.
The work, published Sept. 18 in the journal Science Advances, explores how twisting and bending flexible rods can store energy and then release it in an instant — a "snapping motion" that lets a small machine launch itself forward or push through water. The researchers also built a working prototype to show the idea in action.
Why Frogs Make Good Robots
Frogs are unusually efficient jumpers. They do not rely on enormous muscles to leap; instead they exploit stored elastic energy in their tendons, releasing it rapidly to fling themselves away from predators or across ponds. That biological trick is attractive to engineers because it sidesteps a fundamental constraint of small robots: the smaller a machine gets, the harder it is to pack in powerful motors and the electronics needed to control them.
The study's authors argue that bio-inspired snapping mechanisms could open up a middle ground. Rather than scaling motors up, they suggest building robots whose own physical structure handles part of the work of motion — a strategy that could benefit machines with tight power budgets, or those that must cross uneven ground and even water.
How the Snapping Rod Works
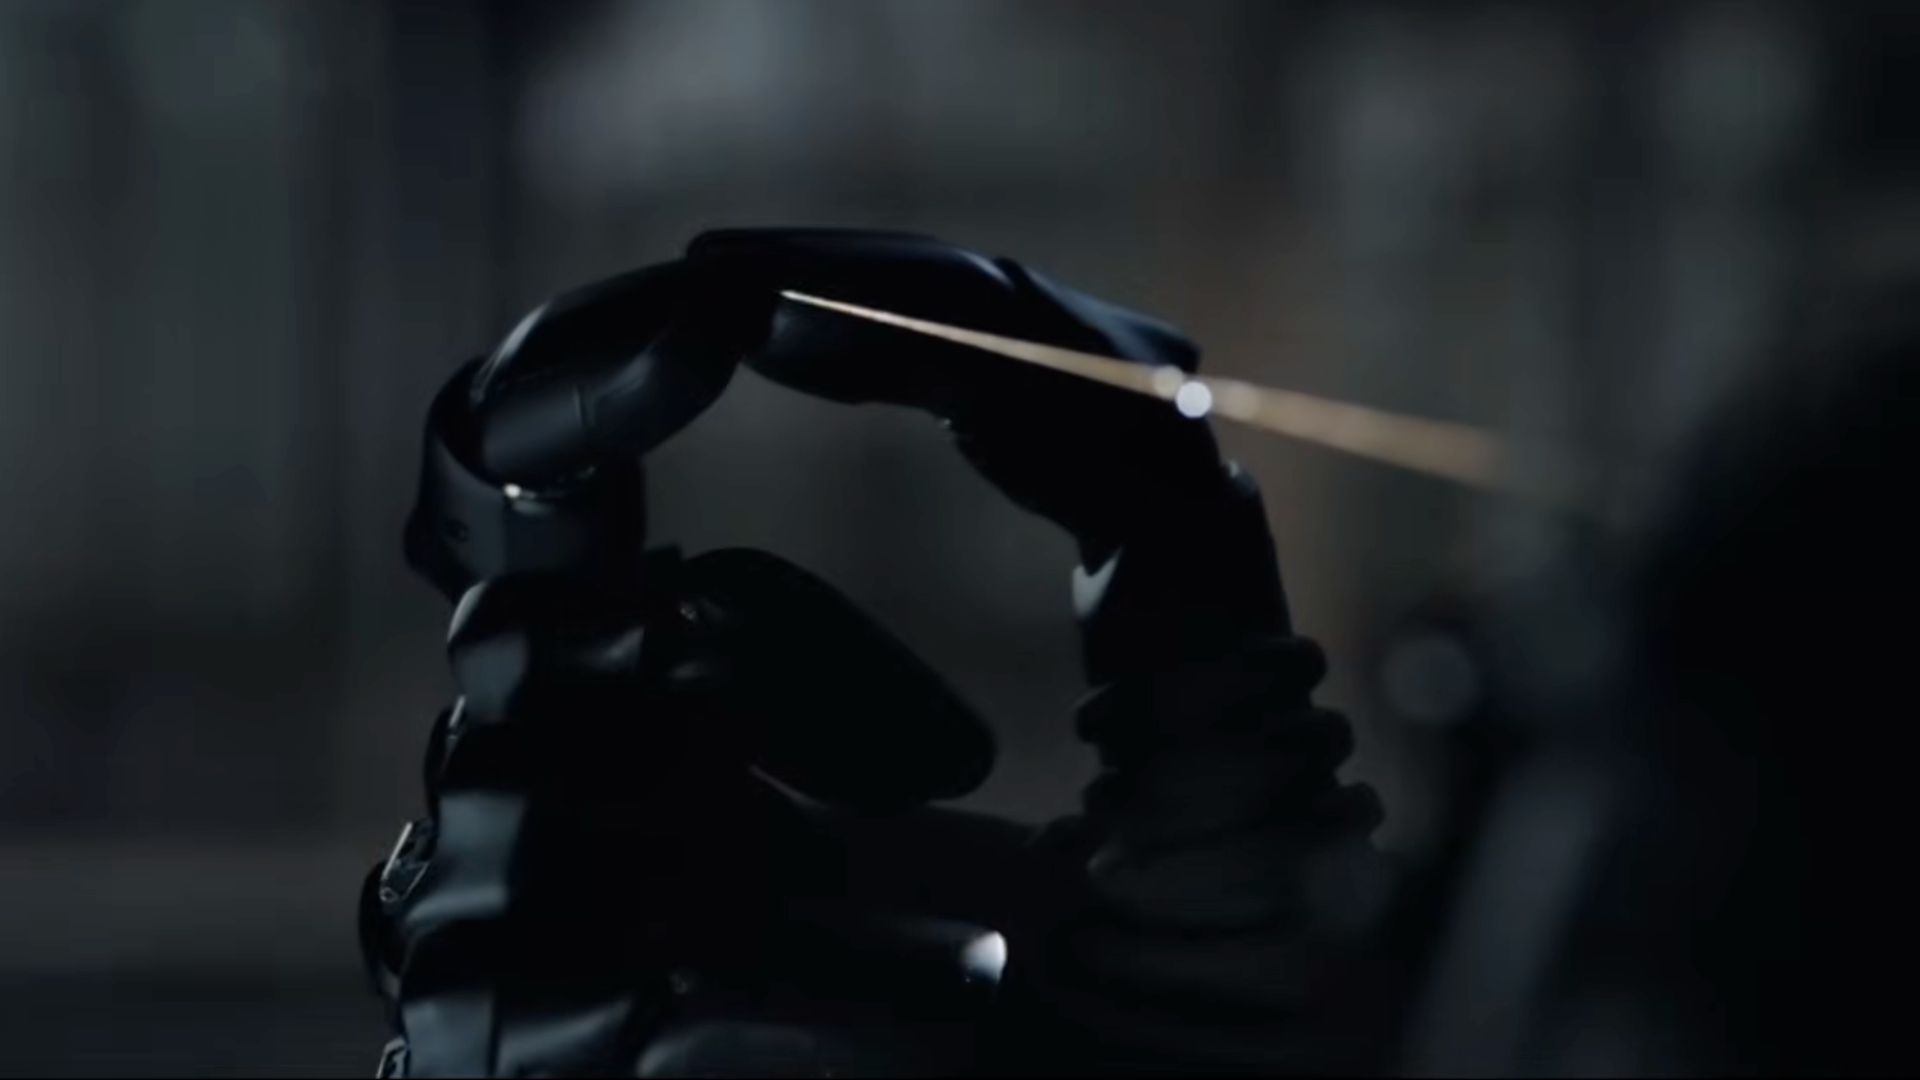
The core of the design is a flexible rod. When the rod is bent into a curve and its ends are rotated, tension builds inside the material. Eventually the rod reaches a threshold where it flips into a new configuration, discharging that accumulated energy in a fraction of a second.
What makes the system interesting — and tricky to engineer — is that this transition is not perfectly predictable. Depending on how bending and twisting are combined, the rod can resolve its stored energy in more than one way. The researchers probed those combinations to understand which configurations produce a reliable, repeatable snap that can be harnessed as a jump.
In effect, the rod acts as a mechanical spring and trigger rolled into one. Program the timing of when energy is stored and when it is released, and the robot gains access to sharp, powerful motions without asking a motor to deliver high output continuously.
A Palm-Sized Prototype
To demonstrate the concept, the team assembled a compact machine whose dimensions are closer to a toy than to a conventional robot. Key figures from the study and the prototype include:
- Weight: roughly 3.4 ounces, about the same as a deck of playing cards.
- Size: small enough to sit in the palm of a hand.
- Speed: about three body lengths per second, achieved through a series of short jumps.
- Capabilities: hopping across wet surfaces, swimming, and navigating an obstacle course.
The obstacle-course demonstration is notable because it tests the robot outside a controlled laboratory setup. A machine that can hop, land, reorient and continue moving has to cope with unpredictability — slick ground, obstacles, and the shift from dry terrain to water — using a simple mechanical repertoire rather than complex onboard computation.
Letting Mechanics Do the Work
Xiaonan (Sean) Huang, an assistant professor of robotics at the University of Michigan and a co-first author of the study, framed the project as a way of redistributing effort between hardware and control software. The broader opportunity, he said in a statement, is to let the mechanics of the robot handle some of the work that would otherwise demand bigger motors or more elaborate control systems.
By programming when an elastic structure stores energy and when it releases it rapidly, Huang explained, engineers can give small robots powerful and repeatable motions without constantly pushing motors to their limits. That framing points to a larger trend in robotics research: instead of adding more actuators and computation, designers are looking for ways to build intelligence and capability directly into a machine's body.

Where Hopping, Swimming Robots Could Help
The researchers describe several settings where a small, energy-frugal machine with amphibious talent might prove useful:
- Cluttered terrain where wheels and tracks struggle, such as rubble or dense vegetation.
- Environments requiring quick obstacle avoidance or sudden reorientation.
- Missions that cross between land and water, where a single locomotion strategy is not enough.
- Deployments where battery capacity or motor output is severely limited by size.
Huang noted that the principle could eventually support robots that must navigate messy, obstacle-strewn ground, overcome barriers, turn themselves around quickly, or operate in both terrestrial and aquatic settings. That combination of agility and efficiency is precisely what makes frogs such effective generalists in the natural world.
What Comes Next
The study is a proof of concept rather than a finished product. Snapping mechanisms are inherently difficult to control precisely, and the fact that a bent and twisted rod does not always release its energy the same way is both an opportunity and a challenge for engineers hoping to build dependable gaits.
Still, the prototype's performance — roughly three body lengths per second across wet ground and water — suggests the approach has room to grow. As researchers map out the relationship between bending, twisting and snapping more thoroughly, they may be able to design elastic structures that deliver specific, repeatable jumps on demand. If that happens, the humble frog may end up shaping a generation of small robots that leap where larger machines cannot follow.
This article is based on reporting by Live Science. Read the original article.
Originally published on livescience.com