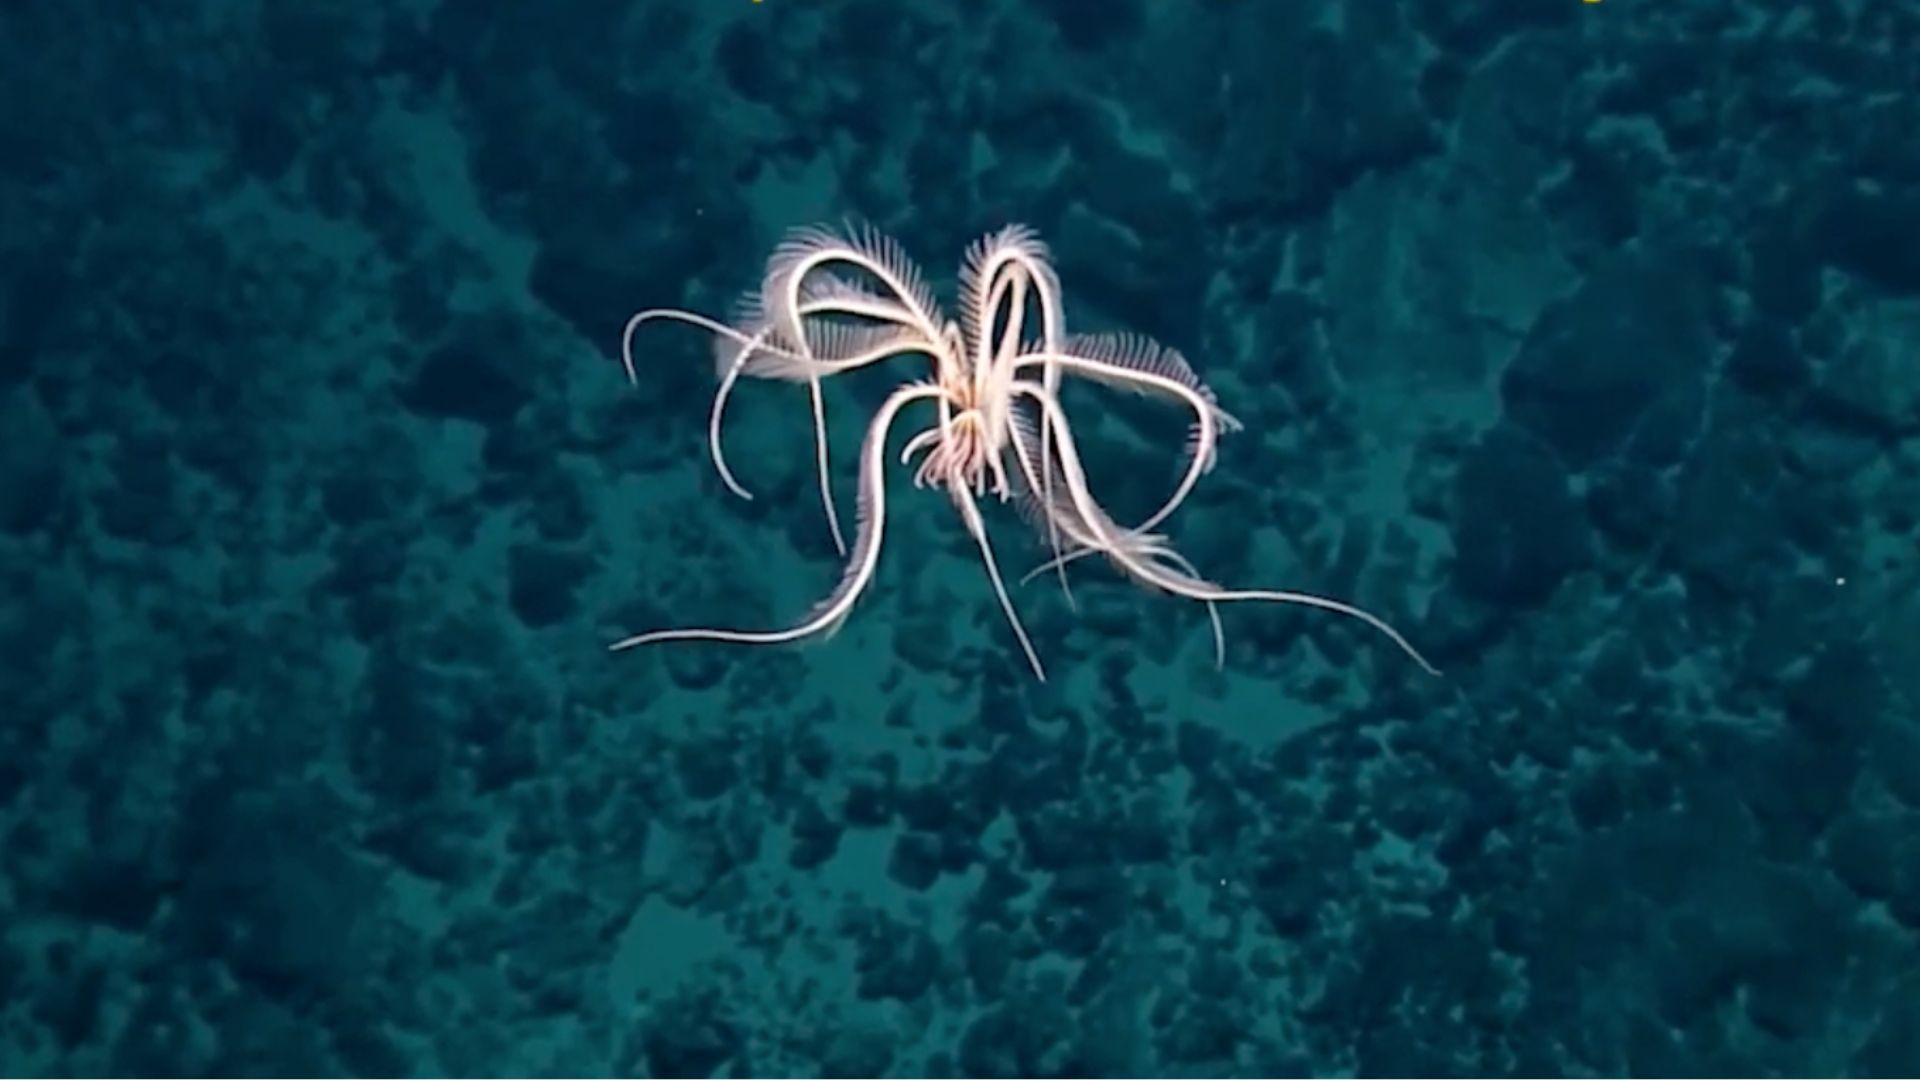
Researchers at North Carolina State University have developed a soft underwater robot whose swimming motion is borrowed from the feather star, a marine animal celebrated for the delicate, rhythmic flutter of its many feathery arms. According to the team behind the project, the machine can move through water freely while relying on just two actuators — an unusually small amount of hardware for a robot expected to propel and steer itself in a fluid environment.
The work sits at the intersection of biology, materials science and robotics, and it lands in a field that has spent years chasing a deceptively simple goal: building machines that swim the way animals do, without the bulk, noise and rigidity of conventional propellers and drivetrains.
The Feather Star as a Design Template
Feather stars are marine invertebrates whose arms are lined with fine, branching appendages. When they swim, the animals do not flap a single fin or spin a propeller. Instead, they coordinate many slender limbs in a traveling wave of motion, creating lift and thrust through soft, flexible structures rather than powerful, concentrated force.
That strategy is attractive to engineers for an obvious reason: it is efficient and forgiving. A rigid mechanism has to be precise, because every joint must move exactly as commanded. A soft, compliant structure can absorb turbulence, bend around obstacles and generate useful motion from a comparatively simple input. The feather star, in effect, offers a blueprint for getting complex behavior out of simple control.
The North Carolina State team translated that idea into a physical platform. Rather than replicating every arm in detail, the robot captures the underlying principle — flexible appendages driven by a minimal set of actuators — so that a small number of moving parts produces a swimming gait that looks and behaves like the animal's.

Why Two Actuators Is a Big Deal
Actuators are the muscles of a robot. Each one adds mass, wiring, sealing requirements and failure points, and underwater that penalty compounds: every additional component is another place where water can intrude, another cable that can fatigue, another draw on a limited power budget.
Cutting the count to two has cascading consequences:
- Simpler sealing and packaging. Fewer moving penetrations into the hull means fewer opportunities for leaks in a corrosive, high-pressure environment.
- Lower power demand. With less actuation hardware to drive, the robot can devote more of its stored energy to swimming and less to hauling its own mechanisms around.
- Fewer failure modes. A two-actuator system has less that can jam, corrode or break, which matters for any machine expected to operate untethered.
- Cheaper builds. Reduced part counts and simpler assembly make it more realistic to produce such robots in numbers rather than as one-off laboratory prototypes.
There is also a research payoff. By showing that a feather star-like gait can be produced with such a lean setup, the team is effectively asking how much of an animal's swimming ability is really about muscle count — and how much is about the geometry and compliance of the body itself.

Soft Bodies, Hard Engineering Problems
Soft robotics is appealing in principle and difficult in practice. A flexible body deforms in ways that are hard to model precisely, so predicting exactly how it will respond to a given command is a genuine engineering challenge. Designers often end up tuning shapes and material properties through iteration rather than deriving them from first principles.
Underwater, those challenges are amplified. Salt water is corrosive, pressure rises with depth, and visibility may be poor or nonexistent. A robot that relies on delicate flexible limbs has to survive contact with sediment, kelp, rocks and marine life without tearing or fouling.
The feather star approach offers a partial answer. Because thrust is distributed across multiple flexible appendages rather than concentrated in a single spinning blade, the machine's interactions with its surroundings are gentler by design. That makes it a plausible candidate for work near fragile environments — surveying seagrass, inspecting structures, or operating in crowded coastal water where a rigid propulsor would be a liability.
A Wider Wave of Field Robotics
The feather star project arrives alongside a broader surge of interest in robots designed for unstructured, real-world settings. In the same AI and robotics coverage stream that surfaced this work, a headline touted a fleet-capable drilling robot reaching ten times the usual speed at 99 percent accuracy — a reminder that field robotics is advancing on multiple fronts at once, from the factory floor to the sea floor.
What unites these efforts is a shift in emphasis. Early industrial robots excelled in tightly controlled environments where every variable could be fixed. The new generation is built for places that are wet, uneven, unpredictable or simply too risky for people to occupy for long. Biological inspiration is one of the most productive routes into that territory, because evolution has already solved many of the same problems under even harsher constraints.
What Comes Next
Turning a laboratory demonstration into a useful platform raises a familiar set of questions:
- Endurance. How long can a small, soft swimmer operate before its power source is exhausted?
- Control. Can the two-actuator gait be steered precisely enough for inspection or sampling tasks, or is it better suited to drifting, exploratory motion?
- Durability. How do the flexible appendages hold up over weeks or months of immersion and contact?
- Autonomy. What sensing and onboard decision-making would let the robot adapt its swimming to currents, obstacles and changing objectives?
- Scale. Does the design work as well when made larger for payloads, or smaller for swarms?
None of these are trivial, and the North Carolina State work is best understood as a demonstration of a principle rather than a finished product. Still, the principle is the interesting part. If a feather star's grace can be approximated with two actuators and a compliant body, then the cost of entry for capable underwater robots may fall considerably.
For an ocean that remains largely unobserved, that matters. Most of the sea is still effectively unmapped and unmonitored, and the limiting factor has rarely been curiosity — it has been the expense and fragility of the machines sent to look. Designs that are simple, cheap and gentle enough to swim alongside living things could change what is practical to explore, and how often.
This article is based on reporting by Interesting Engineering. Read the original article.
Originally published on interestingengineering.com